Data-driven Generalized Predictive Control
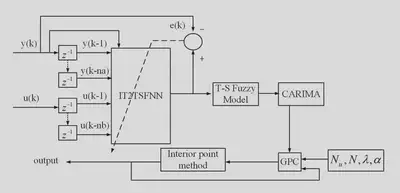
We design a Data-driven generalized predictive control for car-like mobile robots.
Please find the detail from Data-driven generalized predictive control for car-like mobile robots using interval type-2 T-S fuzzy neural network